Nirmal Pol

PhD Candidate, Biomedical Engineering

I’m a PhD candidate in the MEDCVR Lab at the University of Toronto, supervised by Prof. Lueder A. Kahrs.

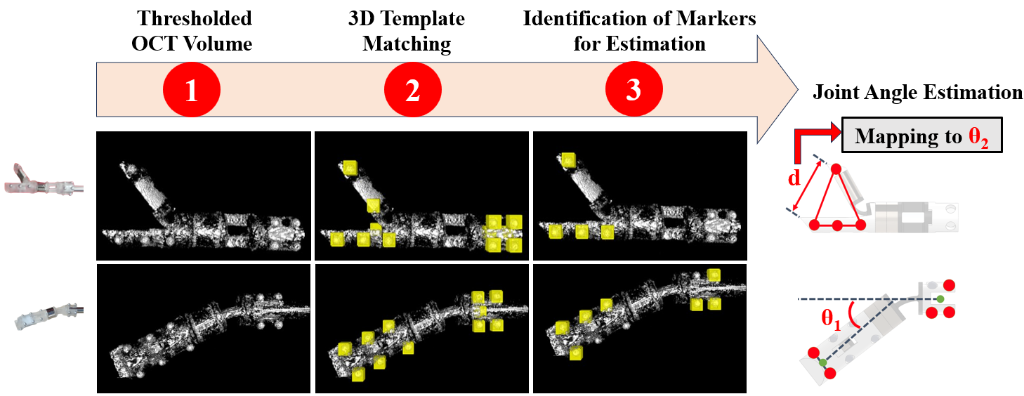
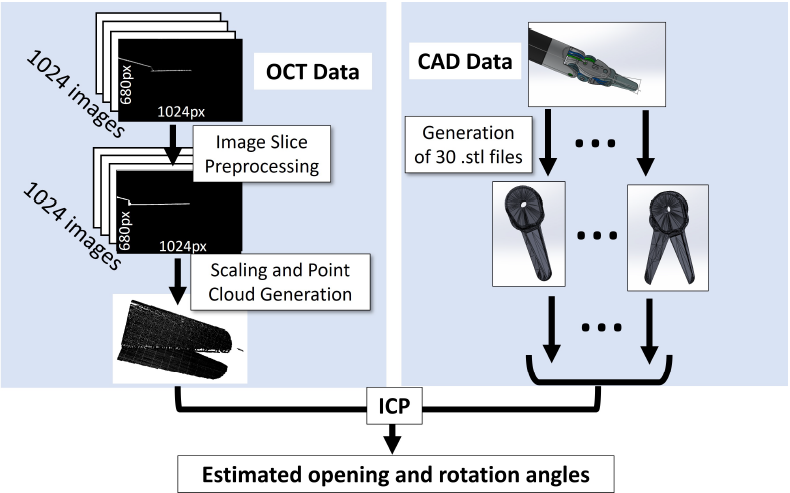
My research focuses on perception and control for surgical robotics. I use optical coherence tomography (OCT), an imaging technique that captures micron-scale subsurface detail, to estimate surgical tool motion and guide precise robotic manipulation.

Nirmal Pol

Publications

* Equal contribution. See my CV for refereed abstracts.

Robotics community

IROS 2026 Competition Organizer

Forceps-Based Fine Manipulation Challenge

Co-organized a hands-on robotics challenge introducing participants to precise teleoperation through needle threading and M2 bolt pick-and-place.

Competition details

My teaching assistant experience at the University of Toronto includes: